Get your free personalized podcast brief
We scan new podcasts and send you the top 5 insights daily.
The founders of Sunday Robotics are making strides by treating data acquisition as a core technical problem. Their innovation lies in developing cheap, practical methods to collect data that mirrors real-world environments, a key and often overlooked challenge in robotics.
Related Insights
To overcome the data bottleneck in robotics, Sunday developed gloves that capture human hand movements. This allows them to train their robot's manipulation skills without needing a physical robot for teleoperation. By separating data gathering (gloves) from execution (robot), they can scale their training dataset far more efficiently than competitors who rely on robot-in-the-loop data collection methods.

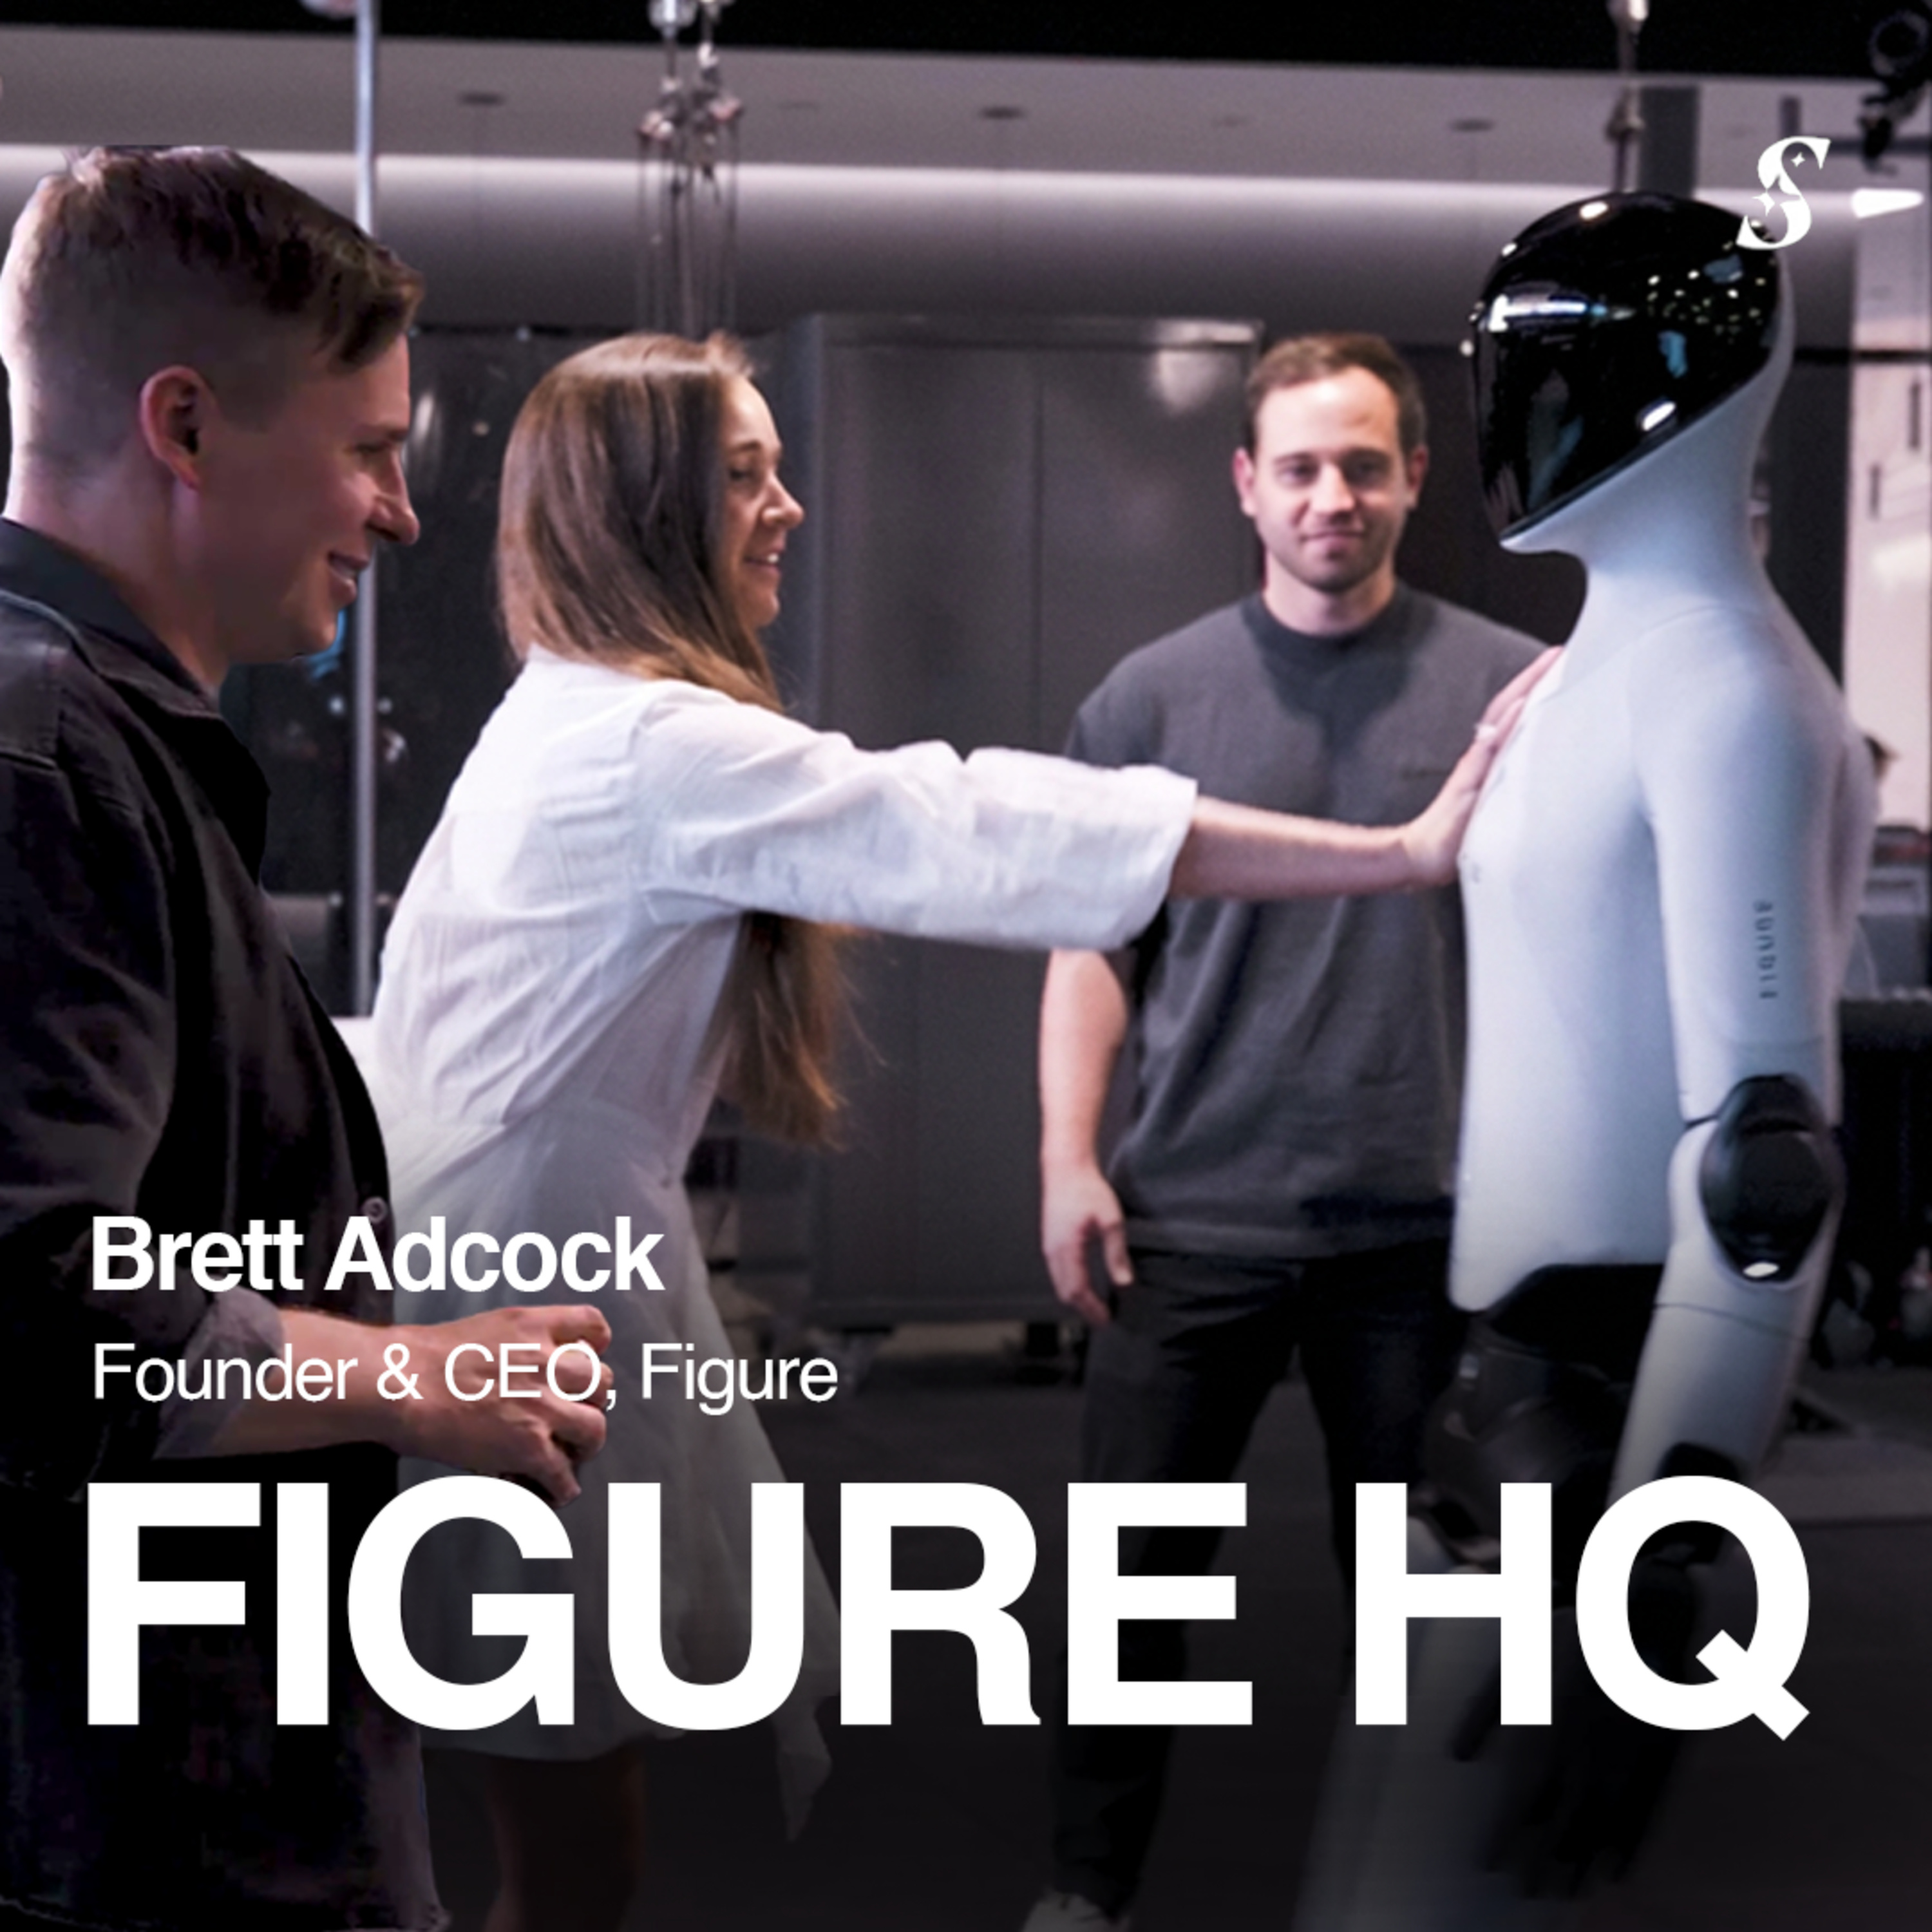
According to Figure's CEO, the company's biggest challenge is no longer hardware reliability but acquiring enormous amounts of diverse, high-quality data. This data is essential for pre-training their Helix AI model to generalize and handle countless real-world scenarios in homes and commercial settings.
Instead of deploying thousands of expensive robots to gather manipulation data, Sunday Robotics is distributing cheaper, specialized gloves. This allows them to collect high-quality, diverse data from humans performing tasks in their own homes, accelerating model development.

The rapid progress of many LLMs was possible because they could leverage the same massive public dataset: the internet. In robotics, no such public corpus of robot interaction data exists. This “data void” means progress is tied to a company's ability to generate its own proprietary data.

Progress in robotics for household tasks is limited by a scarcity of real-world training data, not mechanical engineering. Companies are now deploying capital-intensive "in-field" teams to collect multi-modal data from inside homes, capturing the complexity of mundane human activities to train more capable robots.

The future of valuable AI lies not in models trained on the abundant public internet, but in those built on scarce, proprietary data. For fields like robotics and biology, this data doesn't exist to be scraped; it must be actively created, making the data generation process itself the key competitive moat.

According to Agility Robotics' co-founder, perception is now a largely solved problem. The new frontier is generating training data for robot control—the specific torque commands and sensor inputs for actions. Unlike text or images for LLMs, this data does not exist on the internet and must be painstakingly created.

Firms are deploying consumer robots not for immediate profit but as a data acquisition strategy. By selling hardware below cost, they collect vast amounts of real-world video and interaction data, which is the true asset used to train more advanced and capable AI models for future applications.
For physical AI, the primary constraint is not the cost of data but its fundamental non-existence. Unlike software AI, you can't advance without deploying robots "in the wild" to capture edge cases—a classic chicken-and-egg problem that simulation alone cannot solve and capital cannot easily buy.
For robotics companies, market dominance hinges on a data flywheel effect. This requires rapidly deploying robots into real-world environments, even at a financial loss, because each unit acts as a data source. A small lead in data collection today translates into a massive competitive advantage tomorrow.
